Innomar medium-usv
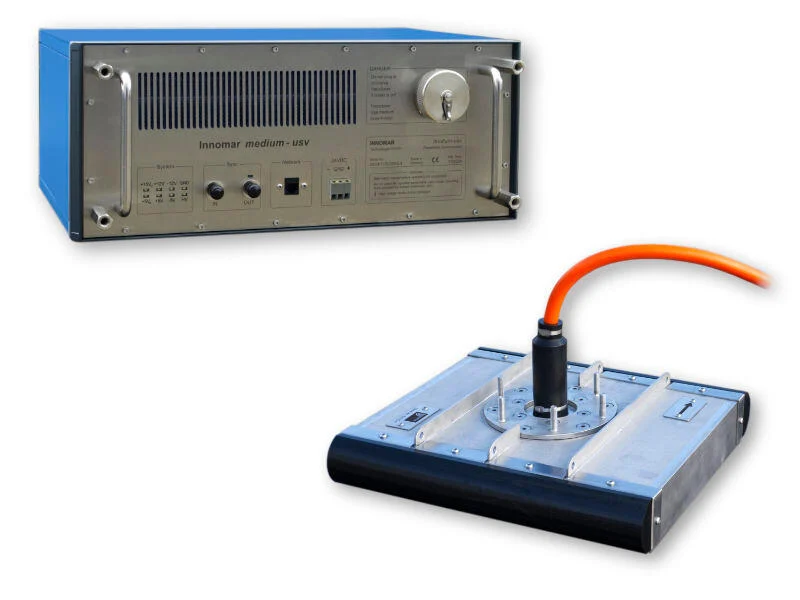
Innomar medium-usv Sub-Bottom Profiler
A high-power USV solution for offshore sediment profiling. Its compact electronics and DC supply are arranged for uncrewed integration, with roll or pitch stabilisation based on external motion data.
Survey applications and configuration
Innomar medium-usv is used to investigate sediment layering and structures below the seabed. Typical project objectives include dredging assessment, route investigation and the interpretation of buried features. The operating mode should be selected against water depth, required vertical detail and the geological conditions. A high penetration figure is a conditional capability, rather than a guaranteed depth in every sediment.
Survey preparation includes the transducer mounting arrangement, measured sensor offsets, positioning input and time synchronisation. An external motion sensor is needed where motion compensation is used. Vessel noise, bubbles and mounting vibration can reduce usable signal quality, so installation and a short acceptance survey should be considered part of the measurement workflow.
Acquisition and processing
SESWIN provides acquisition and system control. Full-waveform records preserve the information needed for later interpretation, and SES Convert supports transfer to established seismic formats including SEG-Y. SES NetView supports remote viewing of system information; ISE is the optional processing environment for Innomar data. Deliverables can be prepared around interpreted reflectors, sediment boundaries and georeferenced profile lines, with the processing method matched to the project specification.
Technical specifications
| Water Depth Range | 2 – 2,000 m below transducer |
|---|---|
| Sediment Penetration | up to 70 m (depending on sediment type and noise) |
| Sample / Range Resolution | c. 1 cm / up to 5 cm (depending on pulse settings) |
| Ping Rate | up to 50 Hz (pings/s), multi-ping mode available |
| Primary Frequencies (PHF) | c. 100 kHz (frequency band 85 – 115 kHz) |
| Secondary Low Frequency (SLF) | centre frequency user selectable: 4, 5, 6, 8, 10, 12, 15 kHz |
| Power Supply | 20–30 V DC, external AC power supply (100–240 V AC) |
| Power Consumption | typ. 100 W, max. 300 W |
Maximum penetration depends on sediment and noise. Resolution depends on pulse settings. Water depth below the transducer is different from housing pressure rating. Confirm the selected configuration against the current manufacturer specification.